Photo

Zhanpeng He

Google Scholar  /  GitHub  /  Twitter
Email: zhanpeng [at] stanford.edu

Zhanpeng He

I am a postdoctoral scholar at Stanford University, working with Jiajun Wu and C. Karen Liu, as part of the Stanford Vision and Learning Lab (SVL) and The Movement Lab (TML).

I obtained my PhD in Computer Science from Columbia University, co-advised by Matei Ciocarlie and Shuran Song as part of ROAM and REAL@Stanford. Prior to Columbia, I start my research journey at USC, where I worked with Gaurav Sukhatme.

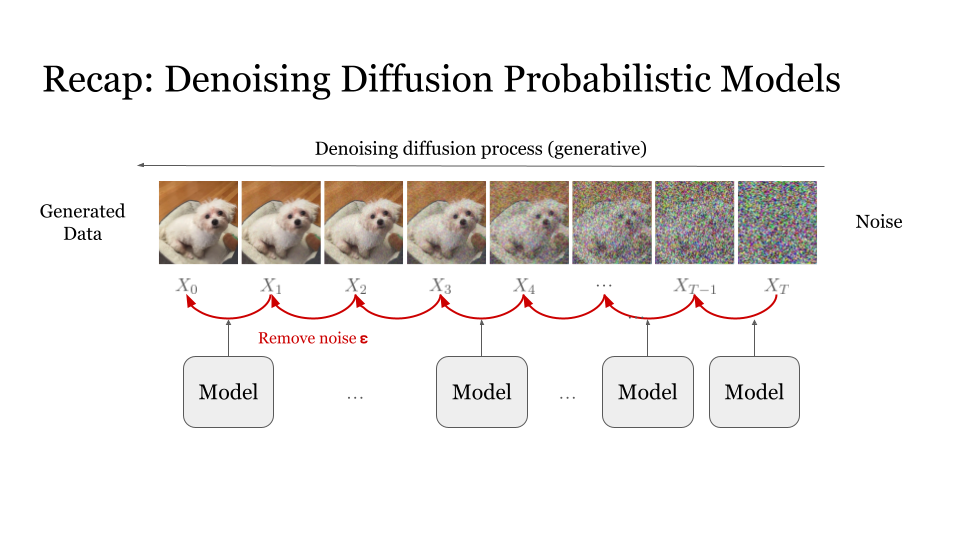
Outside of research, I enjoy cooking, brewing coffee and playing with my dog Nova. Here is a picture of Nova being corrupted by Gaussian noises.

[Stanford] I am seeking motivated undergraduate and MS students for robot learning projects at SVL and/or TML. If you are interested, please fill out this form and send me an email. For Stanford MS students and undergraduates, minimum commitment is 15 hours per week for 6 months.

[External] I welcome collaboration on interesting projects! Please feel free to contact me if you'd like to chat. However, due to my limited bandwidth, I may not be able to respond to all emails.

Research

I'm a full-stack roboticist. I believe robust physical intelligence that works alongside humans won't come from scaling data quantity alone: it also takes the right hardware, the right sensors, and learning algorithms that make the most of both. My research spans:

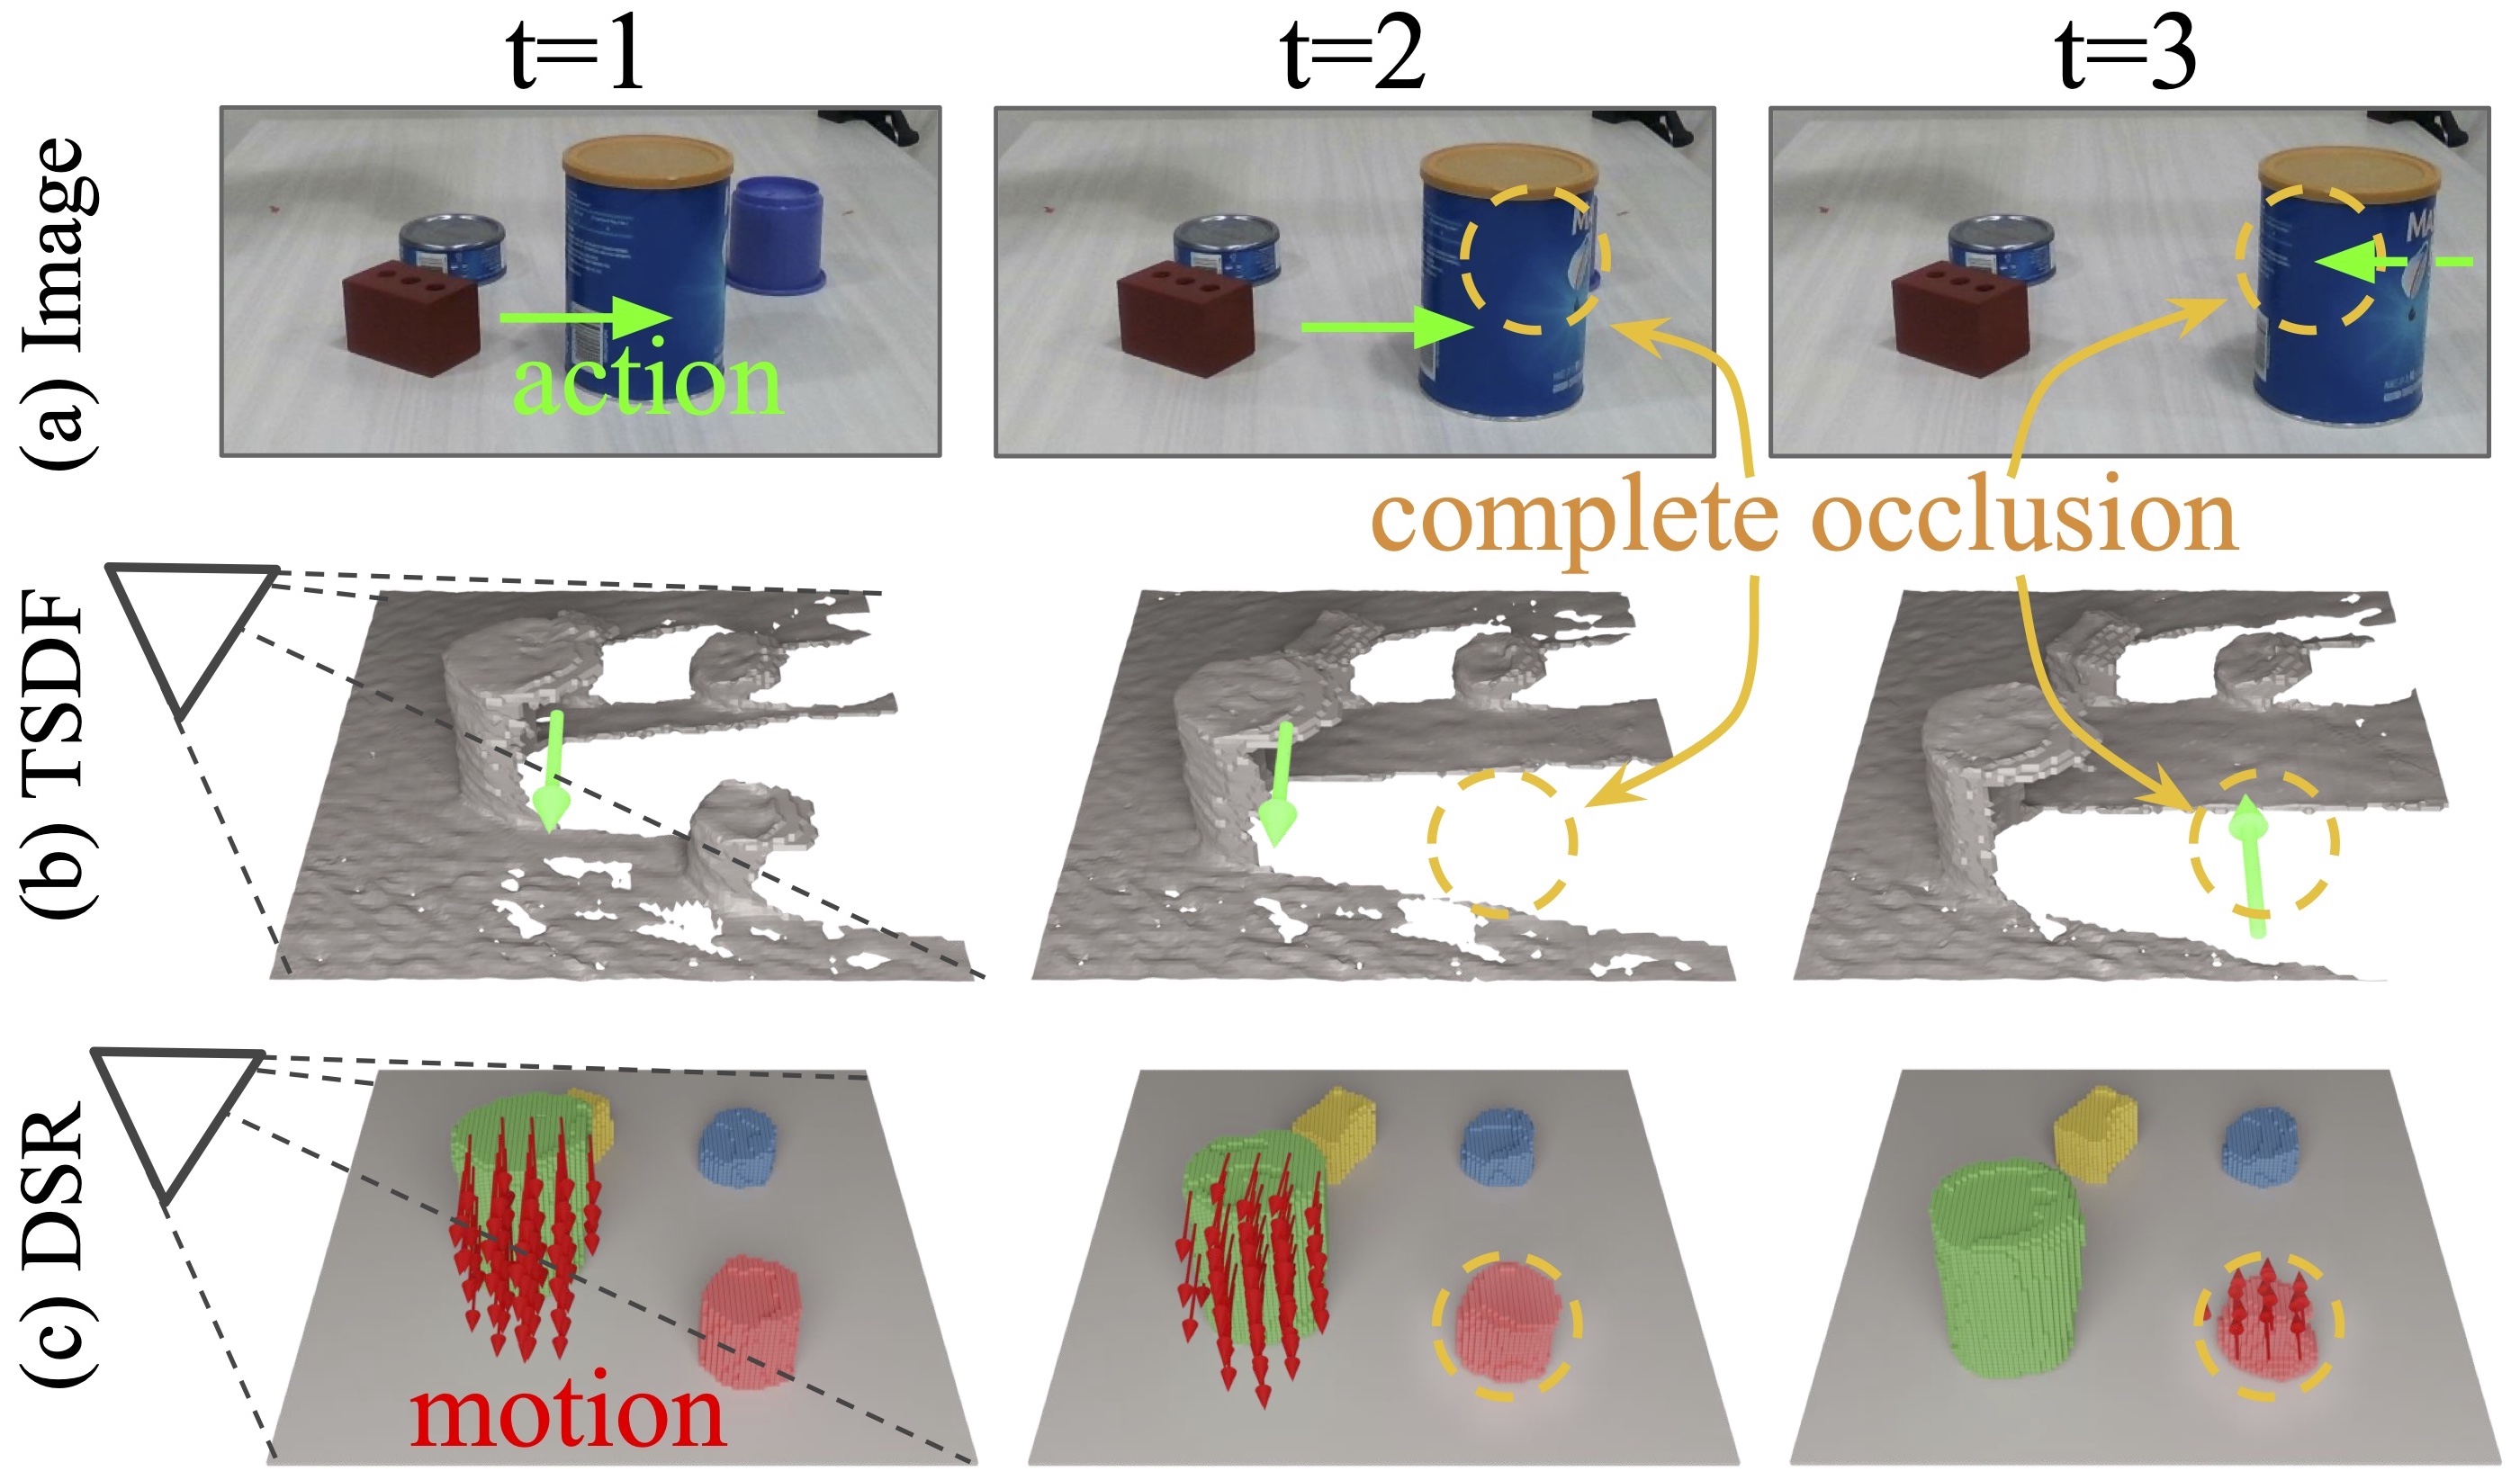
  • Policy learning for dexterity: imitation and reinforcement learning from multimodal sensing [, , , , , ].
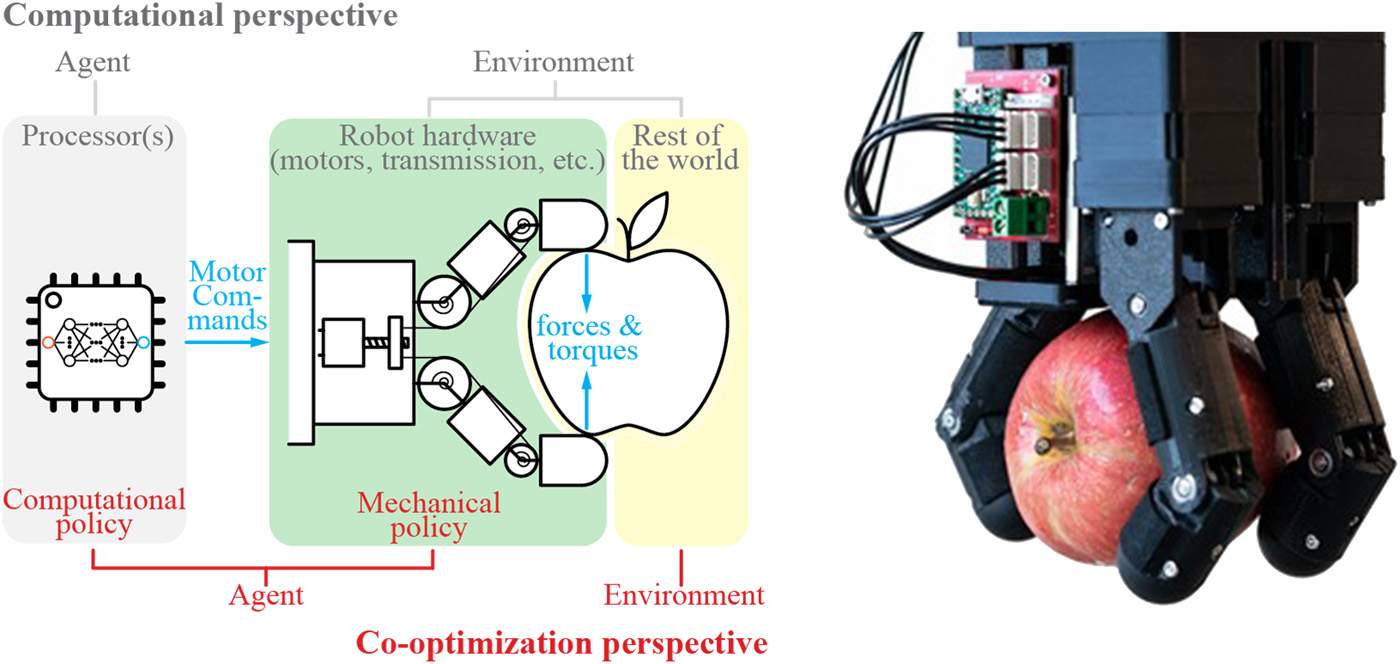
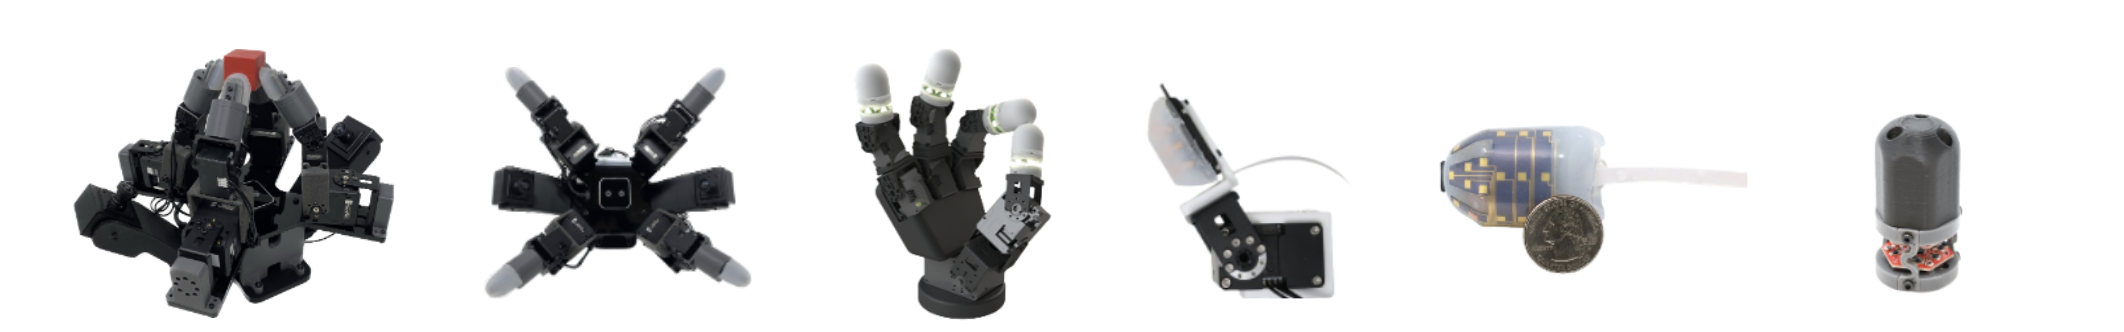
  • Scalable hardware for manipulation: designing manipulators [, ] and multimodal tactile sensors [, ] that make contact-rich tasks easier to learn, teleoperation systems for collecting high-quality data [, ], and methods that co-optimize a robot's body with its policy [, , ].
  • Human–robot interaction: when [, ] and how [] humans should intervene during robot deployment, and how to continually improve policy performance from these interventions [].
News

Publications

(* and † indicate equal contribution and co-first/co-last authors)

The most up-to-date list of publications can be found on my Google Scholar.

Show selectedShow by topicShow all by time

Policy LearningHuman–Robot InteractionTactile SensingHardware Design and Co-OptimizationWorld Models

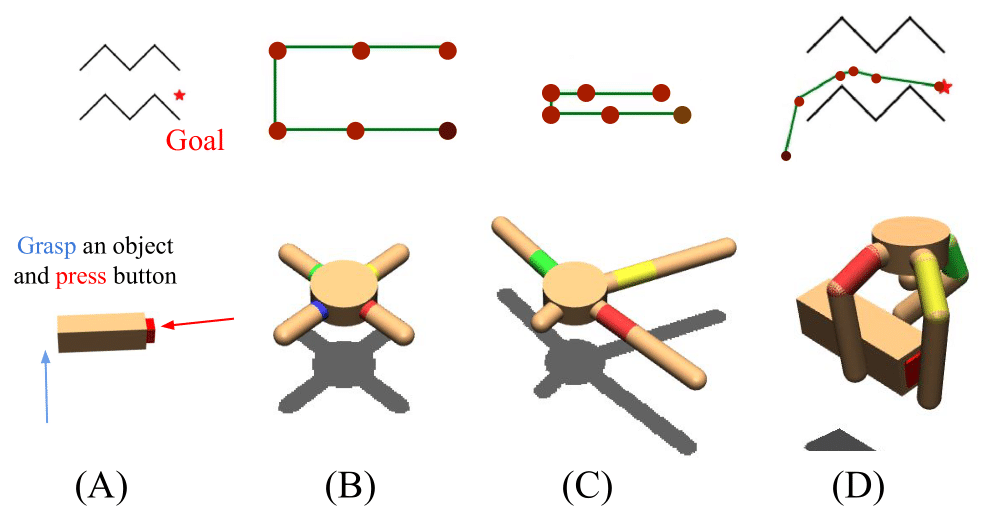
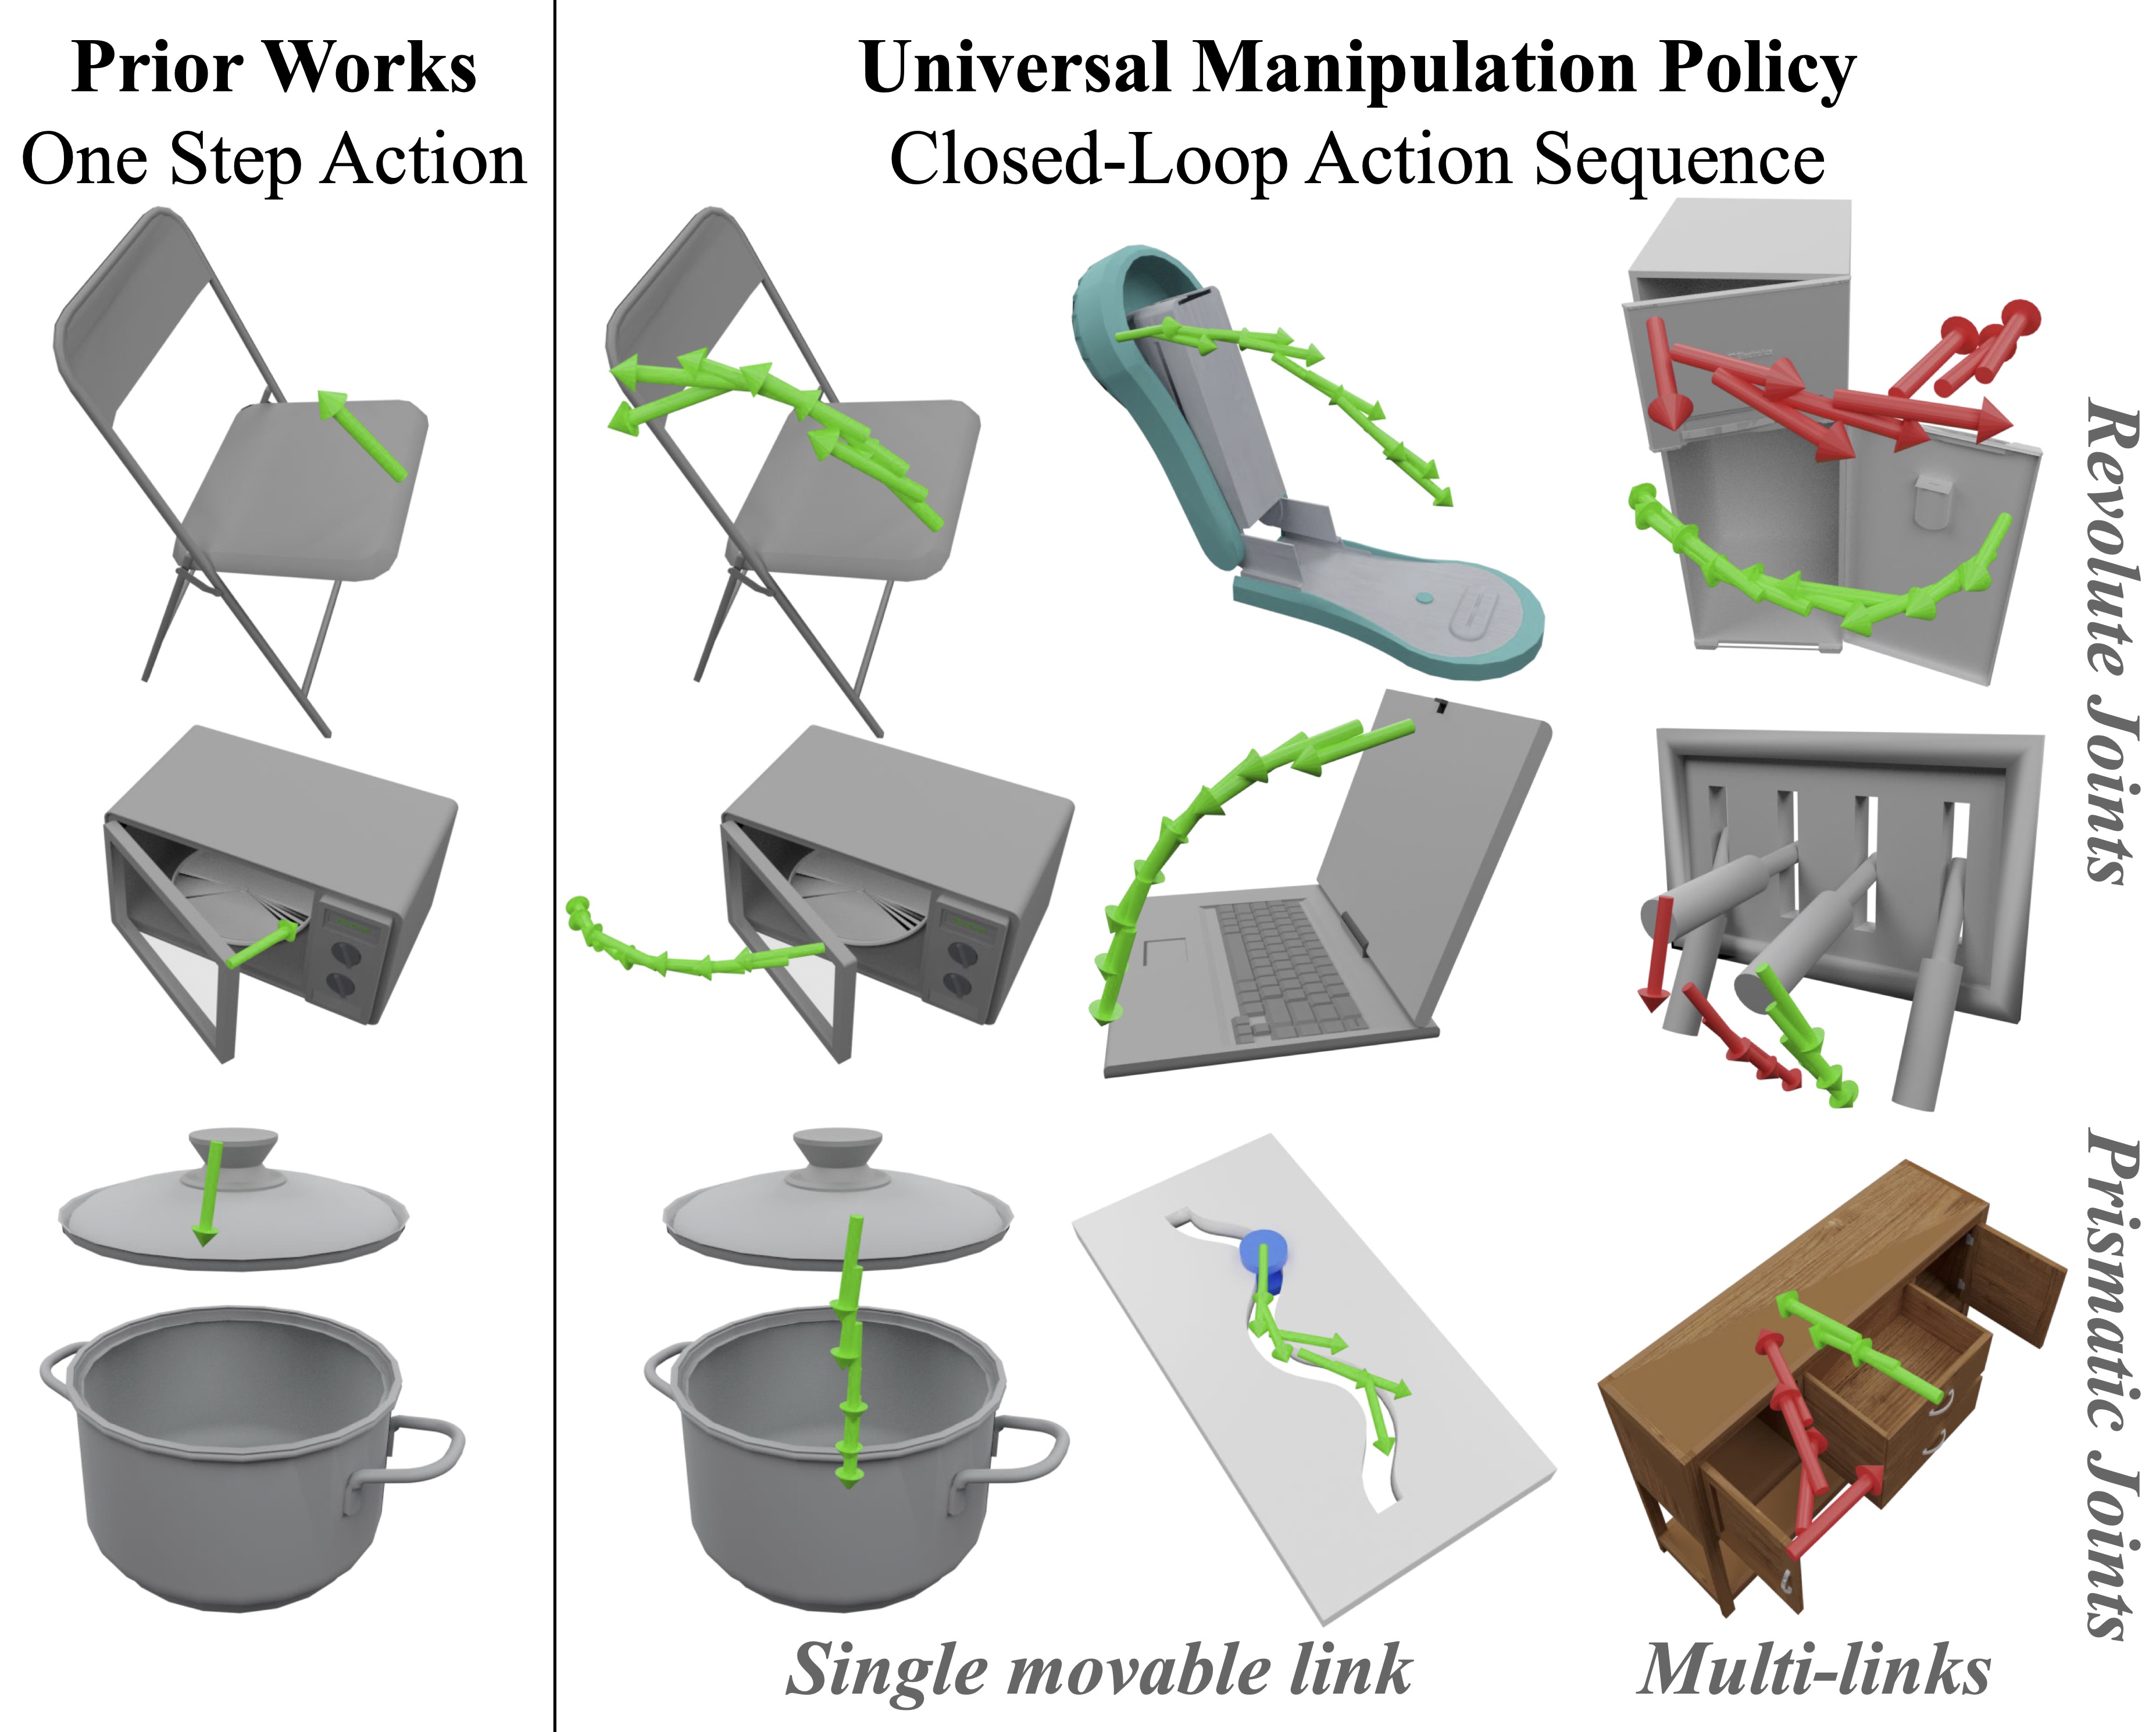
DITTO-X
Zhanpeng He*, Joaquin Palacios*, Zhangyu Wang, Chenhao Li, Katelyn Lee, Matei Ciocarlie†, C. Karen Liu†, Jiajun Wu†
Under review / Website / Paper
DITTO
Joaquin Palacios*, Katelyn Lee*, Edward Zhang, Zhanpeng He†, Matei Ciocarlie†
Under review / Website / Paper
Xiao Liang, Zhanpeng He, Fan Wang, Jiajun Wu, Jane Shi
WACV 2027 / Paper
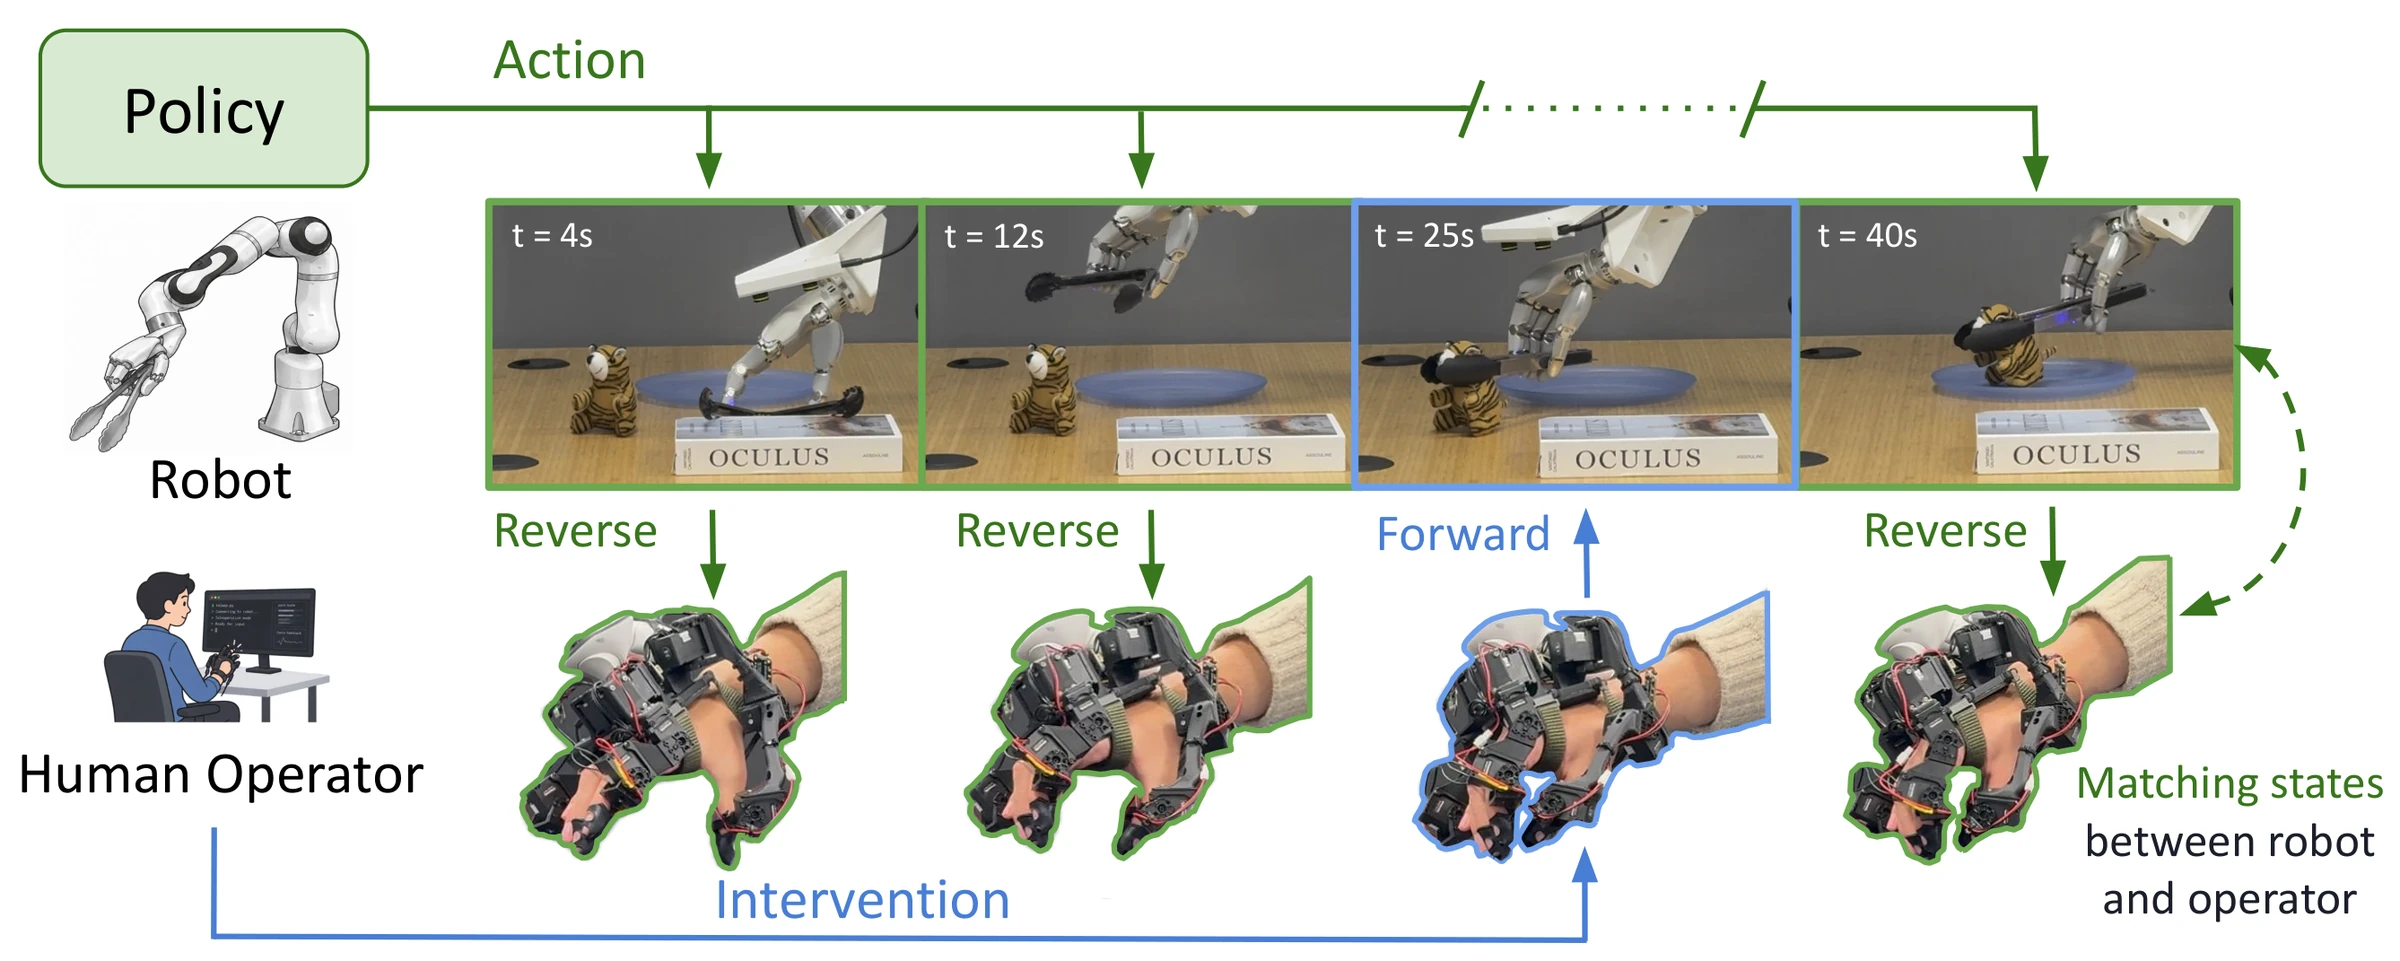
HITL
Zhanpeng He*, Yifeng Cao*, Matei Ciocarlie
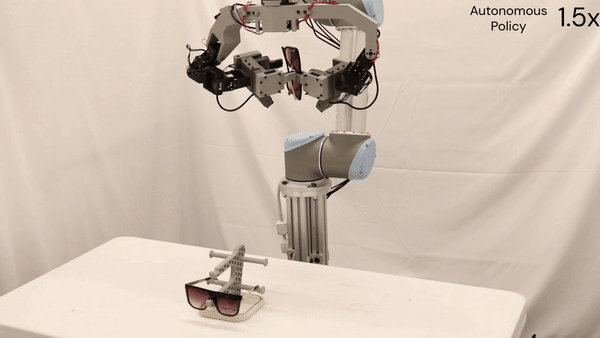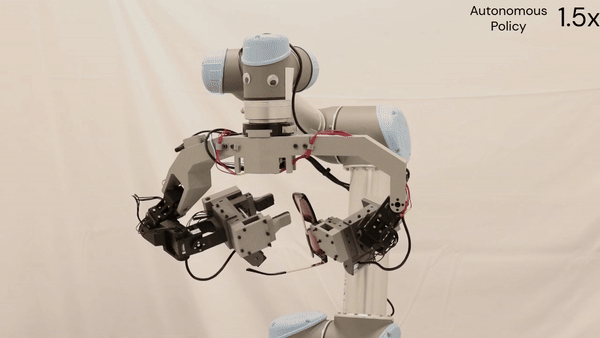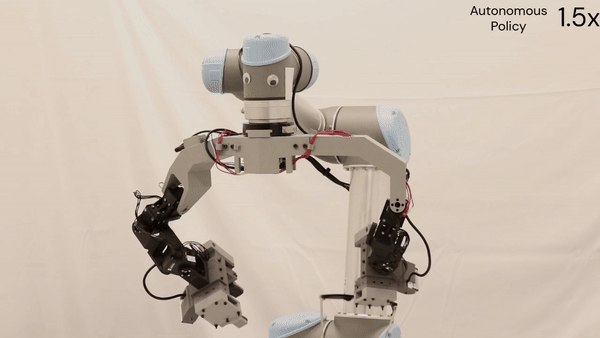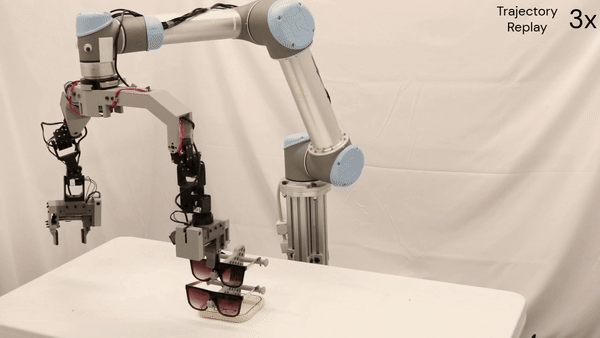
ICRA 2026 / Website / Paper ICRA 2026 Best Paper Award Finalist in HRI (3 / 1882 accepted papers)
SpikeATac
Eric T. Chang*, Peter Ballentine*, Zhanpeng He*, Do-gon Kim, Kai Jiang, Hua-Hsuan Liang, Joaquin Palacios, William Wang, Ioannis Kymissis, Matei Ciocarlie
ICRA 2026 / Website / Paper / WSJ Coverage
MiniBEE
Sharfin Islam*, Zewen Chen*, Zhanpeng He*, Swapneel Bhatt, Andres Permuy, Brock Taylor, James Vickery, Zhengbin Lu, Cheng Zhang, Pedro Piacenza, Matei Ciocarlie
ICRA 2026 / Website / Paper
Meta-World+
Reginald McLean, Evangelos Chatzaroulas, Luc McCutcheon, Frank Röder, Tianhe Yu, Zhanpeng He, KR Zentner, Ryan Julian, JK Terry, Isaac Woungang, Nariman Farsad, Pablo Samuel Castro
NeurIPS 2025 D&B / Paper
Spotlight at CODEML@ICML 2025
VibeCheck
Do-Gon Kim*, Kaidi Zhang*, Hua-Hsuan Liang, Eric T Chang, Zhanpeng He, Ioannis Kymissis, Matei Ciocarlie
IROS 2025 / Website / Paper
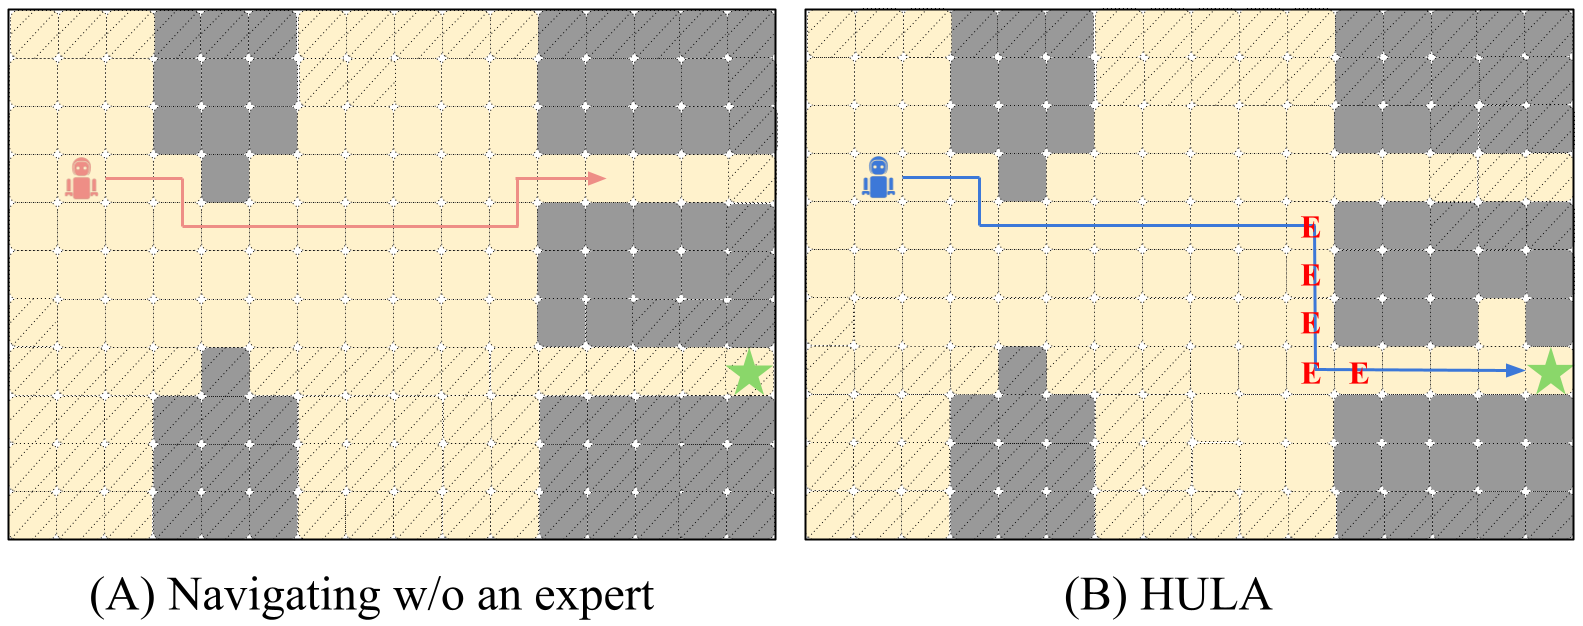
HULA
Siddharth Singi*, Zhanpeng He*, Alvin Pan, Sandip Patel, Gunnar A. Sigurdsson, Robinson Piramuthu, Shuran Song, Matei Ciocarlie
ICRA 2024 / Website / Paper
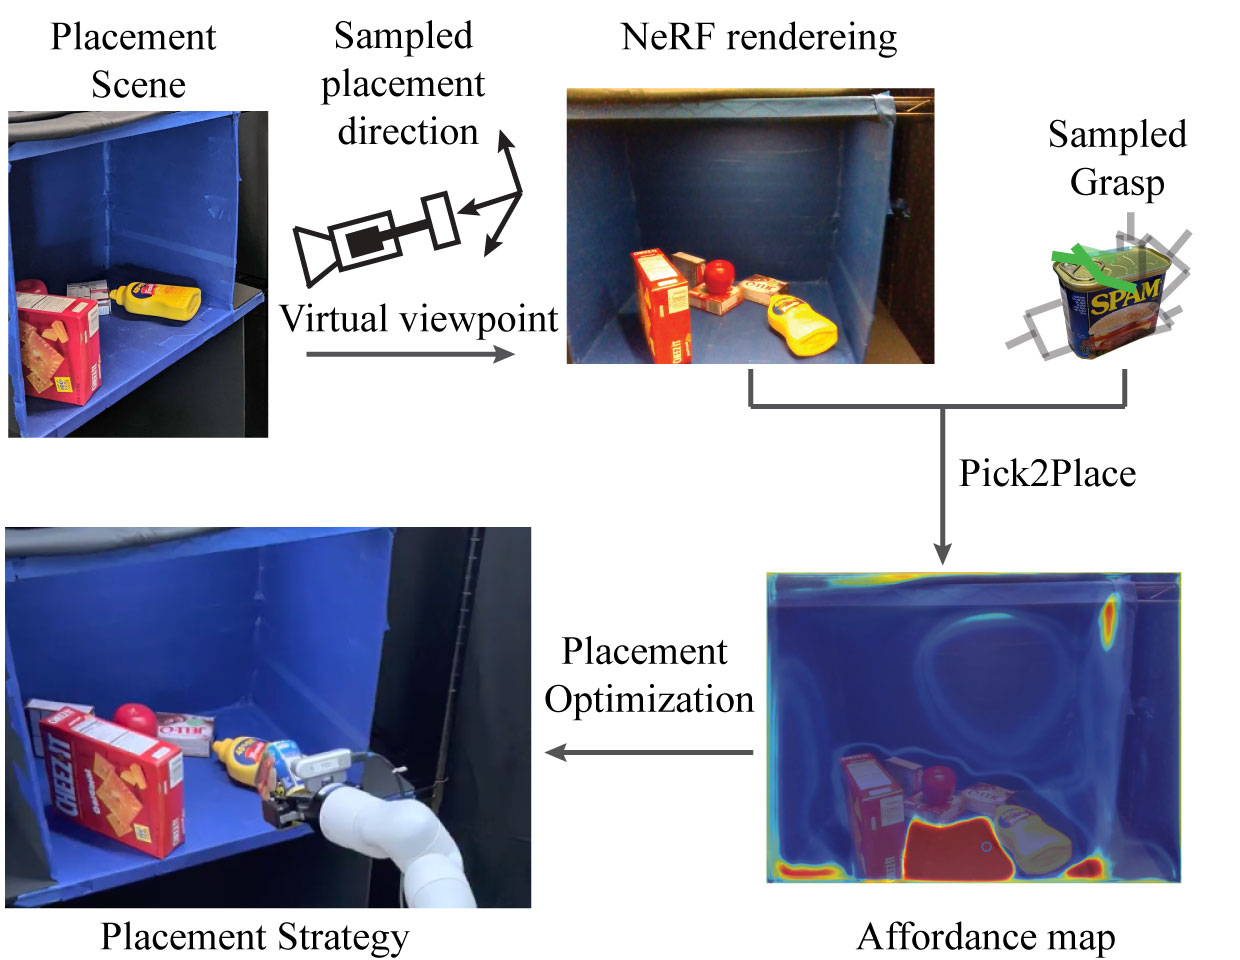
Pick2Place
Zhanpeng He, Nikhil Chavan-Dafle, Jinwook Huh, Shuran Song, Volkan Isler
ICRA 2023 / Paper

Mentoring

Current Mentees
  • Songbo Hu (Stanford Intern)
  • Zhangyu Wang (Stanford Intern)
  • Chenhao Li (Stanford Intern)
  • Jessica Xu (Stanford UG)
  • Kuzey Kantarcıoğlu (Stanford UG)
  • Jennifer Lew (Stanford UG)
  • Mingchuan Cheng (Stanford UG)
Former Mentees

Service and Teaching

Academic Services
Teaching Experience
  • Invited Lecturer: MECE 6616 Robot Learning 2024Spring, 2025Spring
  • Teaching Assistant: MECE 6616 E Robot Learning 2020Spring, 2022Spring